Details
Screenshots & Images
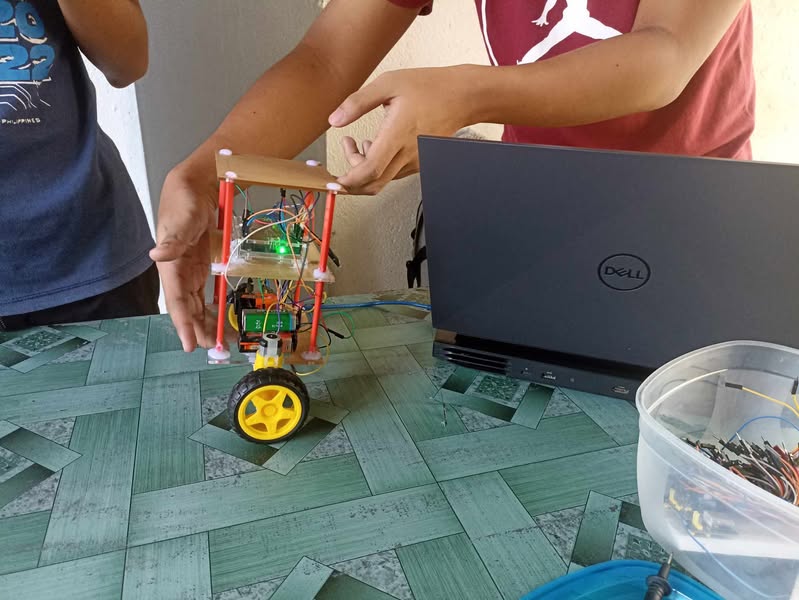
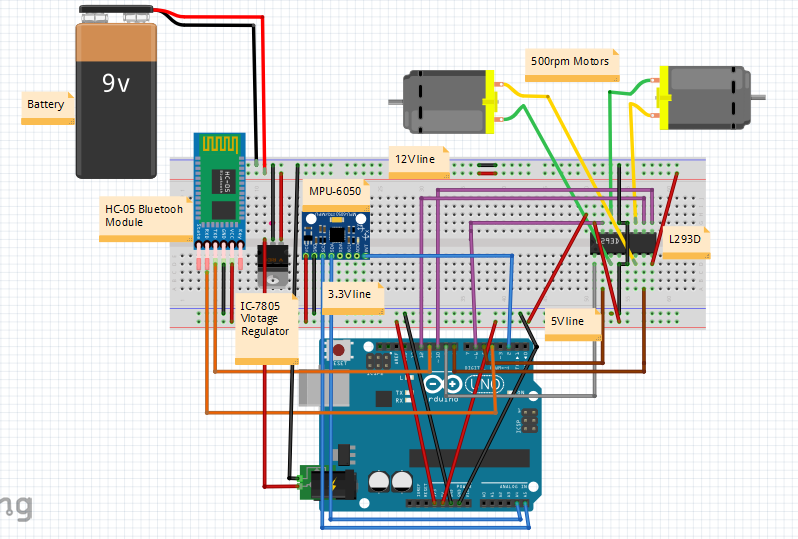
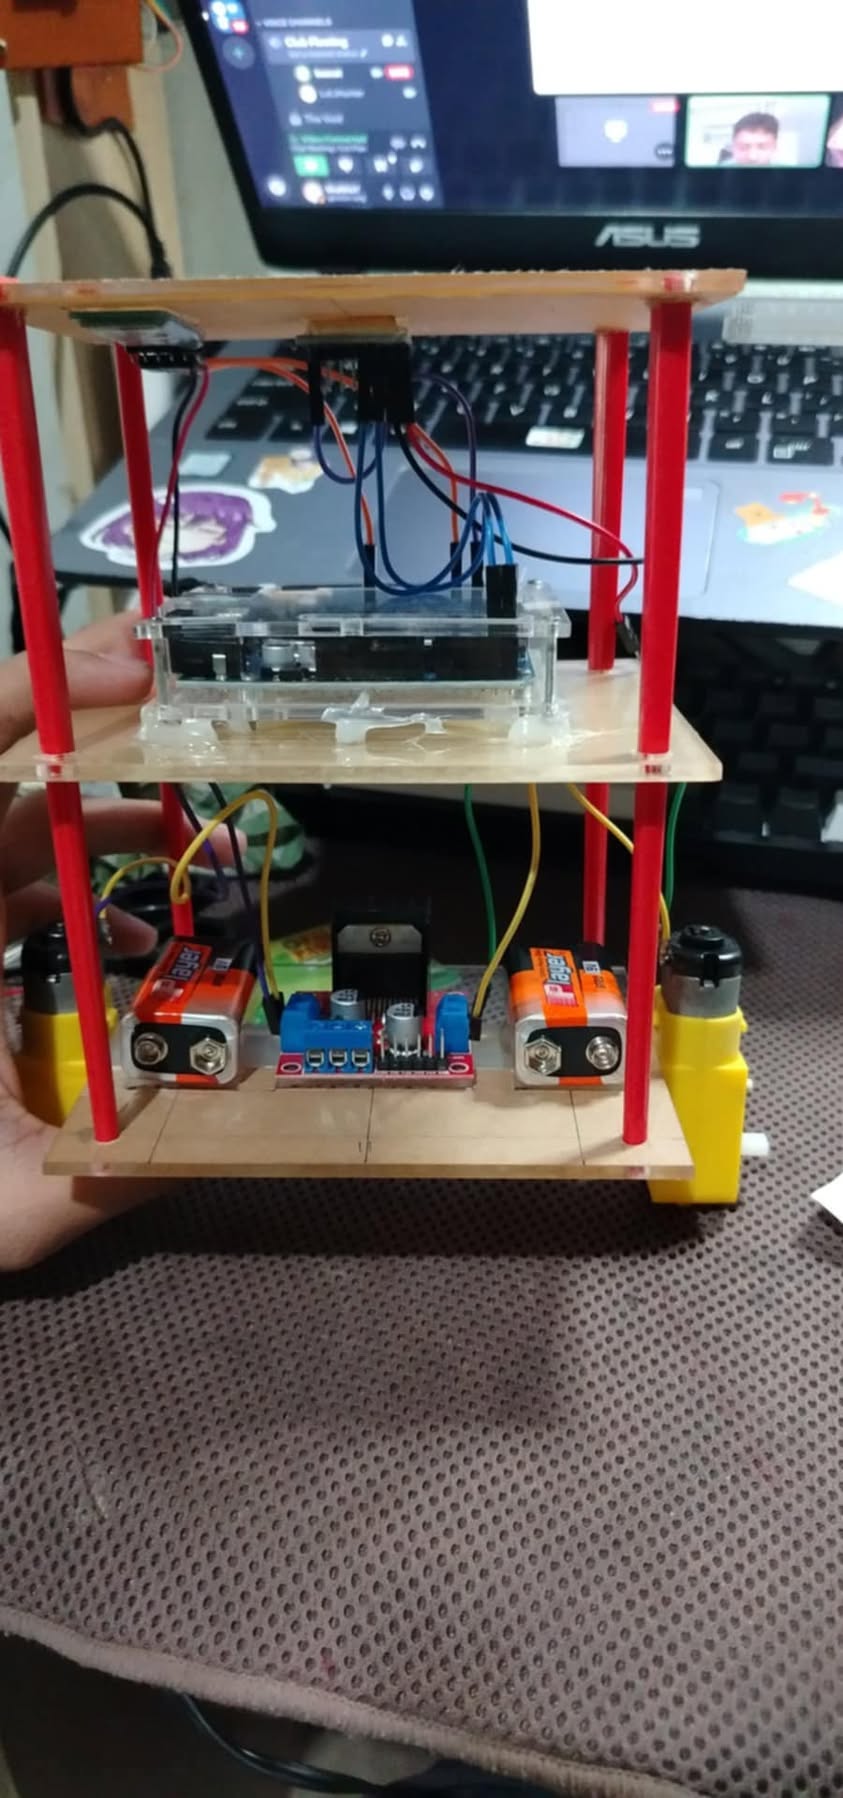
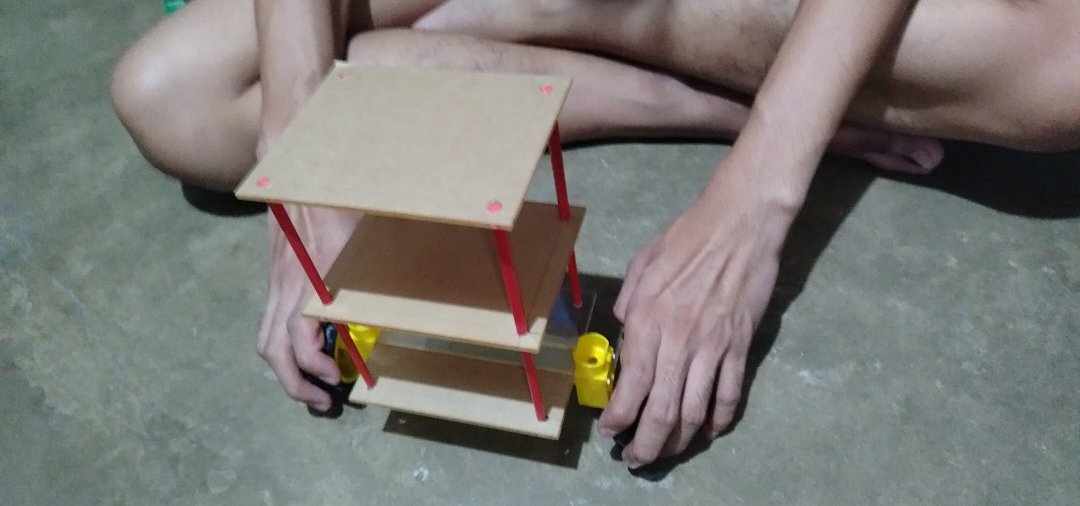
This two-wheeled robot was designed to remain upright by continuously measuring its orientation with an MPU6050 inertial measurement unit. An Arduino processes the sensor data and drives the motors in the direction needed to correct the robot's tilt.
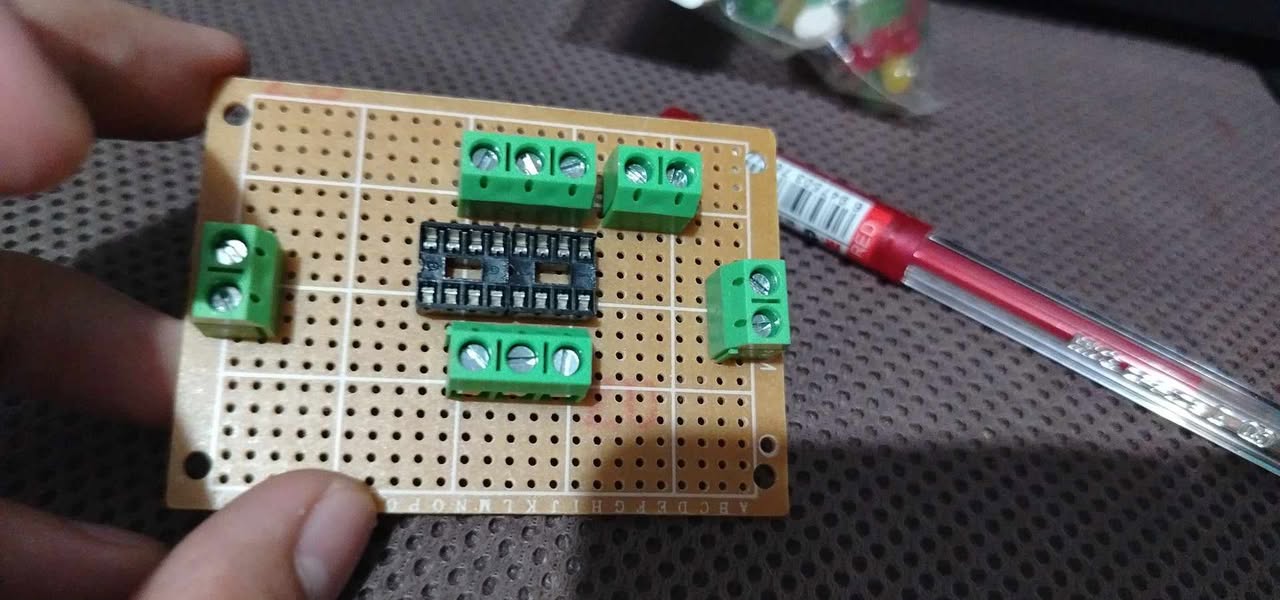
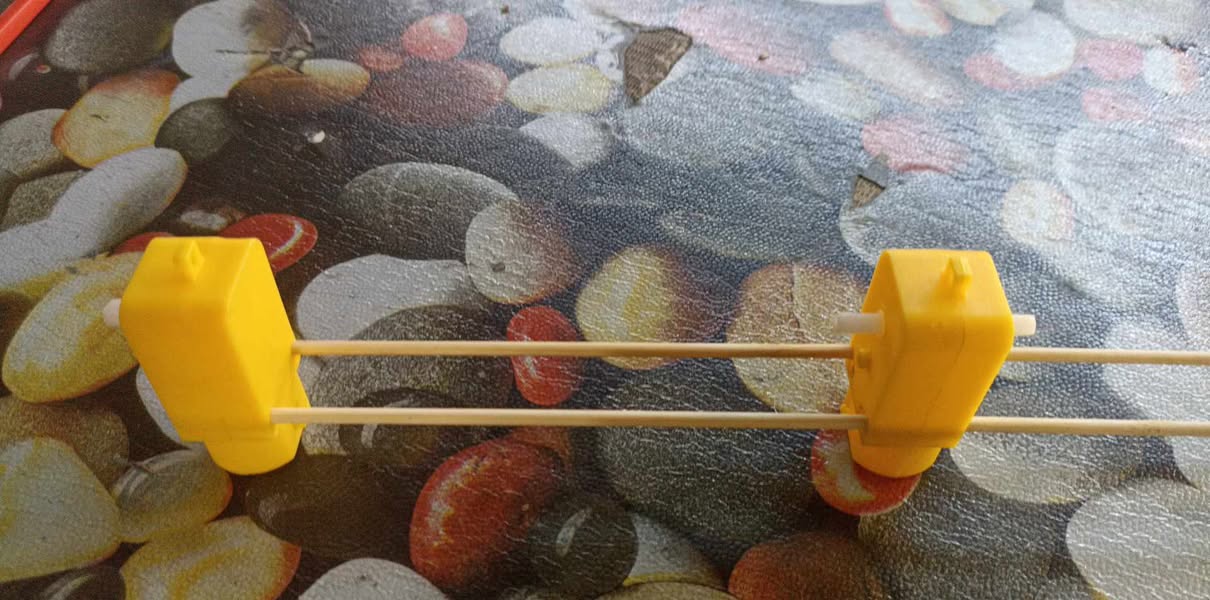
A PID controller converts the measured angle into precise motor corrections. The build involved assembling the frame, wiring the motor driver and power system, calibrating the balance point, and tuning the proportional, integral, and derivative values until the robot could recover from small disturbances.
Bluetooth control was added for directional movement while the balancing loop continues to run. The project combined mechanical prototyping, circuit integration, embedded C++ programming, sensor calibration, and iterative testing in one compact robotics platform.